By VNOVO Technical Support Team
Keywords: Tooth Breakage, Planetary Reducer, Lubrication Failure, Grease Selection, PFPE
The 12th Humanoid Robot Exhibition in Shanghai — 30,000 m², 500+ companies, IFR predicting the global market to exceed 120 billion RMB in 2026. The industry is shouting about mass production.
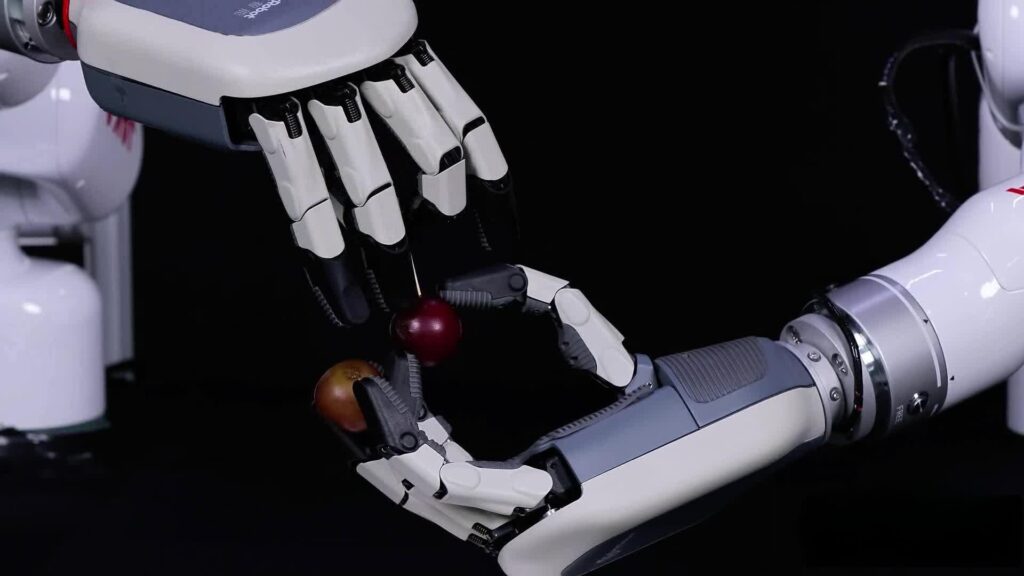
The venue was buzzing. But after talking with several engineers, what kept them up at night was not large models or vision algorithms — it was the planetary reducer in the dexterous hand.
The industry universally reports that planetary reducers in dexterous hands start showing abnormal noise, precision degradation, and in severe cases, tooth breakage. Materials changed, suppliers changed, imported replaced with domestic, domestic replaced with imported — conditions are roughly the same.
Where is the problem?
Planetary Reducers in Dexterous Hands Are Far Harder to Work With Than Industrial Grade
A planetary reducer structure is like a miniature solar system: a sun gear at the center connected to the motor input, rotating around it are 3 to 4 planet gears, the outer ring of planet gears is a fixed internal tooth ring, and all planet gears output power through a common carrier.
But the planetary reducer in a dexterous hand operates in a completely different environment from industrial robotic arms.
Space is limited, grease fill quantity is extremely low. Dexterous hands are extremely compact — available grease volume is only a fraction of industrial grade. The lubrication system’s margin for error is virtually zero.
High-frequency forward-reverse, the same area bears alternating peak loads. Industrial robotic arms operate primarily in forward rotation, while every grasp by a dexterous hand completes a forward-reverse cycle. Both upper and lower track surfaces simultaneously bear peak Hertz stress, and the alternating stress amplitude at the tooth root zone is far greater than in unidirectional operation.
Temperature rise is difficult to dissipate in compact space. Heat accumulation effect is much more severe than standard conditions. Under high-frequency start-stop, temperature fluctuations are dramatic, placing higher demands on grease high-temperature stability.
Overload impact far exceeds industrial applications. The Hertz stress peak during grasping often exceeds the design limit, and the grease oil film response speed under impact load directly determines whether metal-to-metal contact occurs at the tooth surface.
These four factors — the effect is not addition, it is multiplication.
How Tooth Breakage Happens
Tooth breakage in planetary reducers never occurs in an instant — it is a slow accumulation chain of failure.
Phase 1: Lubrication failure, tooth root stress concentration. The centrifugal force field generated by planet gear revolution continuously throws grease away from the mesh zone. Oil film gradually thins. When oil film thickness is insufficient, micro-protrusions at the tooth root — the position of maximum gear stress and highest stress concentration — experience direct contact. Local high temperature occurs near contact points, tooth root surface hardness decreases, and strain hardening effect is weakened.
Phase 2: Micro-crack initiation and propagation. High-frequency forward-reverse in dexterous hands means the tooth root zone bears periodic tensile-compressive alternating load. Under sustained alternating load, the stress concentration effect at the tooth root fillet causes local stress to exceed the material’s fatigue limit. Micro-cracks begin initiating from 0.5 to 1 mm below the tooth root surface — that is the depth of maximum shear stress from Hertz contact stress. Early crack propagation is slow; nothing abnormal is visible externally, the machine still runs normally, just noisier than when new.
Phase 3: Crack acceleration. Once a crack propagates to the surface, grease enters the crack interior, and under periodic load “pumping effect,” crack propagation accelerates. The most obvious signals at this stage: bearing temperature rise intensifies, vibration increases, and noise frequency sharpens. Tooth root cracks continue propagating simultaneously in the tooth width and tooth depth directions. The gear’s effective load-bearing cross-section becomes smaller and smaller.
Phase 4: Overload fracture. When the crack propagates to a critical size, the effective load-bearing area can no longer withstand the peak load during grasping. The gear suddenly fractures under a single load — this is why in many cases there is no obvious warning before tooth breakage. Because the main crack has already transversely penetrated the entire tooth root cross-section before becoming visually apparent.
Once tooth breakage occurs, the entire finger joint is essentially unrepairable — only complete replacement is possible. Repair cost is 50% to 200% of new unit price. Even more troublesome: after one gear breaks, the load redistributes to the remaining gears, stress multiplies, and tooth breakage begins spreading to other gears — the entire reducer is soon scrapped.
How Grease Stops This Failure Chain
For the above failure chain, grease selection must address several core indicators.
Extreme pressure anti-wear is the first hurdle. Planetary reducer contact pressure is 1 to 3 GPa. Grease must have sufficient extreme pressure additives to generate FeS/FePO₄ metallic protective film in high-pressure contact zones. Without this mechanism, under heavy impact loads metal direct contact occurs, adhesive wear accelerates fatigue crack initiation, and the tooth breakage process is greatly accelerated.
Adhesion is the second hurdle — also a unique challenge for planetary reducers compared to other reducer types. Planet gear revolution generates a centrifugal force field that continuously throws grease away from the mesh zone. This is the primary reason ordinary industrial grease fails in dexterous hand applications.
If thickener adhesion is insufficient, grease does not survive more than a few ten-thousand cycles before being thrown away. Even the best extreme pressure additives cannot function without a lubricating medium — tooth surfaces remain in an unprotected state for extended periods.
High-temperature stability is equally critical. The grease dropping point determines the upper working temperature limit. Mineral oil-based grease dropping point typically does not exceed 200°C. Under sustained high-frequency operation, internal temperatures in dexterous hand planetary reducers easily exceed 100°C, and long-duration operation approaches 150°C. When approaching or exceeding the dropping point, the thickener structure softens, grease begins to be lost, tooth surfaces lose lubricating protection, friction heat increases dramatically, and temperature continues rising — entering a vicious cycle.
Shear stability cannot be ignored. Continuous shearing from centrifugal force causes grease to thin. Apparent viscosity decreases. Oil film thickness becomes insufficient to bear designed loads. Tooth root stress concentration areas become more likely to induce fatigue cracks.
The Industry’s Verified Optimal Solution: Fluorinated Oil + PTFE System
Perfluoroether base oil (PFPE) working temperature range is -90°C to +250°C — the widest temperature range of any base oil type. Combined with PTFE thickener, adhesion and anti-centrifugal throw-off performance are excellent. In the centrifugal force field generated by planet gear high-speed revolution, it can remain in the mesh zone much longer. Extreme pressure anti-wear additives are responsible for generating metallic protective film in high-pressure contact zones. PTFE microparticles can actively cover crack tips when microscopic damage has already occurred, slowing micro-crack propagation speed.
Bench data: On a dedicated test bench for dexterous hand planetary reducers, the X500 solution ran continuously for 100,000 cycles with no visible pitting on tooth surfaces and no abnormal crack propagation in the tooth root zone. Compared with ordinary grease, which began showing obvious wear marks at approximately 30,000 cycles. Converting to actual usage time, the X500 grease replacement cycle is extended by three to four times.
The Bottom Line
The industry is indeed exploding. Global humanoid robot shipments grew over 508% year-over-year in 2025. China’s market is expected to approach 9 billion RMB in 2026. But if the lubrication problem in dexterous hand planetary reducers is not solved, at the 10,000-unit scale, each unit’s annual maintenance cost of 2 to 3 times plus joint replacement fees — that number will not look good.
Next time you do maintenance, try opening it up: Are there pits on the tooth surface? Any abnormal discoloration in the tooth root fillet zone? Any spalling marks on the planet gear bearing raceway? These are direct indicators of whether lubrication has failed.
Search “VNOVO” or visit our website for more information.