By VNOVO Technical Support Team
Here is what happened.
Figure recently announced that in 120 days, they scaled production from one unit per day to one unit per hour. 24 times.
Then Japan Airlines announced they would be introducing Figure. Industrial applications are starting to run. Everything is accelerating. Everything is in overdrive.
To be honest, when I saw this news, my first reaction was: How fast.
But the second reaction immediately followed: At this pace, will anything go wrong?
I have been following the humanoid robot track for a while, and this time I want to discuss a very specific but critical issue: tooth breakage in dexterous hand planetary reducers.
The larger the production scale, the more this becomes a batch problem. And once it becomes a batch problem, the loss is not just about replacing a few gears.
Mass production increase is both honey and arsenic
Let me start with some background.
The core bottlenecks in humanoid robot mass production are actually two: joint modules and dexterous hands. The dexterous hand is the most precise and most frequently used module in the entire robot system.
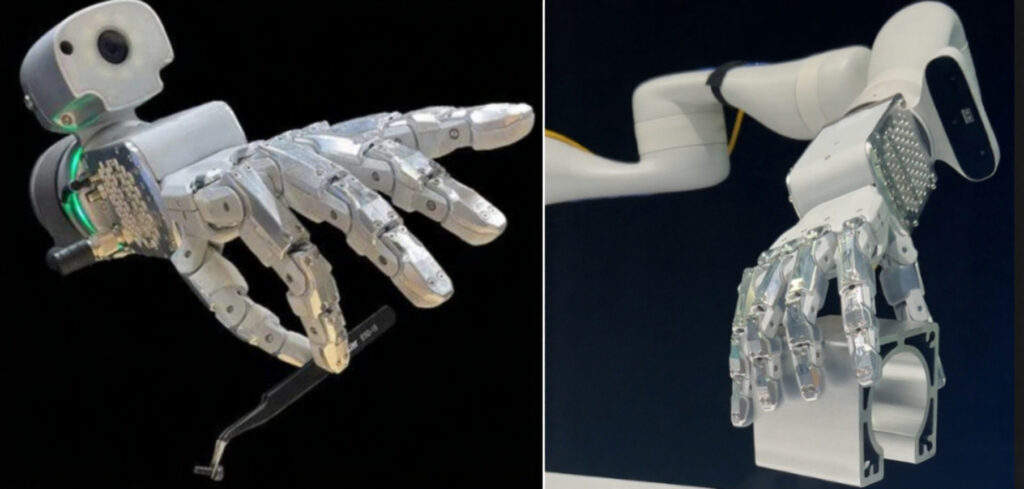
How frequently?
A single humanoid robot performs dexterous hand open-close operations over 100,000 times per day with ease. Inside each finger joint sits a micro planetary reducer, typically with an outer diameter of 15mm or less. The module size is as small as 0.15-0.3mm, with a tooth width of only 12mm.
What does this size mean?
It means roughly that in an area about the size of a fingernail, more than a dozen gears smaller than a sesame seed are packed in.
What does scaling from one unit per day to one unit per hour mean?
It means the number of parts produced at this size multiplies by 24 overnight. Any batch quality fluctuation, any lubrication deviation in any process step, any assembly precision error will all be amplified 24 times.
And then buried inside robot finger joints.
Waiting to explode.
How does tooth breakage actually happen?
Many people think gear tooth breakage is a sudden snap.
It is not.
Tooth breakage is a complete failure chain.
Step one: Root micro-cracks quietly initiate.
The operating state of dexterous hand planetary reducers is very special — high-frequency start-stop. What does high-frequency start-stop mean? It means impact loads arrive every few seconds.
Peak impact load is typically 2-3 times the static load. This force directly strikes the gear tooth root.
The gear tooth root is the most stress-concentrated location on the entire gear. The stress concentration factor is typically 1.5-2 times the average tooth surface stress. Under high-frequency impact, as the metal undergoing cyclic tension-compression loading at the microscopic scale, cracks quietly initiate at this most vulnerable location.
Silent and invisible.
By the time you can detect them, it is often already too late.
Step two: Insufficient lubrication, cracks begin accelerating.
The problem is the lubricating grease.
The space in dexterous hand joints is extremely limited. The clearance between the reducer housing and internal components is only a few hundred microns. Ordinary grease, under high-frequency shear and centrifugal force fields, is easily thrown out of the meshing zone.
Once the oil film drops below 0.5 micrometers — a thickness comparable to tooth surface roughness — the metal at the gear tooth root crack begins direct contact. Without lubrication protection, micro-cracks act as if on fast forward.
There is a figure that left a deep impression on me: when a gear tooth root has an initial crack of 0.3-0.5mm, with good lubrication, delaying its propagation to critical size can exceed tens of thousands of hours. Without lubrication, the same crack may develop to the tooth breakage threshold within a few thousand hours.
A few thousand hours sounds long. But for a humanoid robot planned for commercial operation, this timeframe may be just a few months.
Step three: Snap. The joint seizes.
Once one gear tooth breaks, its original load instantly distributes to adjacent gears. Then a chain reaction begins — the remaining gears work under overload, failing in hundreds to thousands of hours.
Tooth breakage is contagious.
And if a robot dexterous hand joint seizes, the entire machine must be taken offline for repair. The cost, you can estimate yourselves.
Why do ordinary greases fail to handle this?
Here is a very real problem.
The working conditions of dexterous hand planetary reducers impose almost contradictory requirements on lubricating grease:
Extremely small space — the reducer housing cannot hold much grease, yet enough must be filled without affecting shaft flexibility.
Extreme temperature fluctuation — gear temperature rises rapidly during high-frequency finger operation, then drops quickly after shutdown. Thermal cycling tests the stability of the grease greatly.
Centrifugal throw-off resistance — micro planetary wheels rotate at high speed; grease must firmly adhere to gear surfaces; being thrown to the housing edge equals failure.
Silent operation — dexterous hand joint working noise must be controlled below 35dB. Grease friction characteristics directly affect this indicator.
Ordinary mineral oil-based grease, under the triple combination of high-low temperature cycling, centrifugal force fields, and boundary lubrication, often begins degrading within 2,000 hours.
But a commercially operating humanoid robot requires joint module life targets starting from 8,000 hours.
A four-times gap.
This four-times gap is the breeding ground for tooth breakage.
How does VNOVO X500 address this?
At this point, I must discuss the X500 dexterous hand joint dedicated grease.
This product was designed from the start for the stringent conditions of dexterous hands. Two core features: fluorinated oil plus PTFE.
First, fluorinated oil.
X500 uses perfluoropolyether (PFPE) base oil — the highest chemically stable base oil type currently known. Temperature range from -90 degC to +250 degC, extremely wide. Completely chemically inert to oxygen, ozone, acids and alkalis — meaning it will not have any adverse reactions with the micro bearings and seals inside the dexterous hand.
This is very important for robot joints operating long-term in complex environments.
Then PTFE.
PTFE is polytetrafluoroethylene. You may be more familiar with another name — Teflon. Its molecular structure is extremely smooth with an extremely low friction coefficient. During the boundary lubrication phase at startup instant, PTFE forms a solid protective cushion between the tooth root and tooth surface.
What does this mean?
It means at the moment when the oil film has not yet fully formed, PTFE steps in first, avoiding initial damage from direct metal contact.
Fluorinated oil provides wide-temperature-range chemical stability and long life. PTFE provides solid lubrication backup during the boundary lubrication phase of high-frequency start-stop. Together, they suppress the initiation and propagation speed of gear tooth root micro-cracks.
Additionally, X500’s low-noise characteristics deserve attention — PTFE’s fine texture combined with fluorinated oil’s low friction characteristics better meet the 35dB silent operation requirement for dexterous hand joints.
Closing thoughts
Figure’s production surge is a milestone for the entire industry.
But behind the milestone is an extreme test of every link in the supply chain.
The tooth breakage problem in dexterous hand planetary reducers will not automatically disappear just because production doubled a few times. On the contrary, the larger the scale, the higher the probability that any lubrication oversight in any link will be amplified by the multiplier.
The cost of replacing a joint module is enough to outfit the dexterous hands of hundreds or thousands of robots with X500.
Is choosing the right lubricating grease the highest cost-performance preventive investment?